Description
Overview
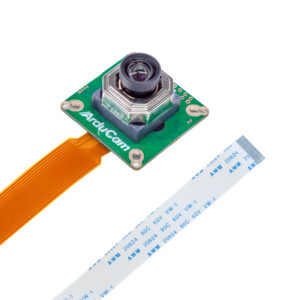
A Time of Flight camera module featuring a MIPI-CSI 2 connection and offering up to 4-meter measuring range with sub-2cm precision, designed and optimized exclusively for Raspberry Pi & Nvidia Jetson boards.
Quick sum-up about the camera:
- Real-time point cloud and depth map.
- Resolution: 240×180@30fps on RPI4/CM4
- Up to 4M measuring distance
- Onboard 940nm laser for both indoor & outdoor uses, no external light source needed.
- V4L2-based video kernel device
- C/C++/Python SDK for userland depth map output and example source code
- ROS ready.
- 38 x 38mm board size
Specifications
| Number of Effective Pixels | 240×180 |
| Image Size | 1/6″ |
| Max. Frame Rate (Sensor) | 120fps |
| Max. Depth Frame Rate (Raspberry Pi) | 30fps, 4-phase |
| Max. Depth Frame Rate (Nvidia Jetson**) | 30fps, 4-phase |
| Raspberry Pi OS | Bookworm/Bullseye (32-bit/64-bit) 01/28/22 or later releases |
| TDP | 3.5W Power supply for Pi should be at least 5V/4A |
| Supported Platforms*** | Pi 5/4/3B/2/CM3/4B/Zero W/Zero 2 W/CM4/Nvidia Jetson Board |
| Modulation Frequency | 75MHz/37.5MHz |
| Viewing Angle | 70° Diagonal |
| Measurement Distance | Far Mode: 4m Near Mode: 2m |
| Light Source | 940nm VCSEL illuminator |
| Board Size | 38mm x 38mm |
| Interface | MIPI (2-Lane) |
| Output Formats | 4-phases RAW Frame, Depth Frame, Grayscale Amplitude Frame |
Documentations
- Getting Started with Arducam ToF Camera
- Getting Started with Arducam ToF Camera (PDF)
- Arducam ToF Camera SDK
- Point Cloud With Arducam ToF Camera
- Getting Started with Nvidia Jetson
- Github – Arducam ToF
- 3D Model of ToF Camera
Packing List
- 1 x Arducam ToF Camera Module
- 1 x 15-15pin FPC Cable (15cm)
- 1 x 15-22pin FPC Cable (15cm)
- 1 x 2-pin Dupunt Cable
*To use the camera on Pi Zero and 2 W, the 15-22pin cable is included.
** Tested on Jetson Orin NX/Orin Nano.