In the race for Embodied AI and Physical AI, data is the ultimate differentiator. While simulators can get you far, training robots to perform complex, fine-grained tasks requires high-quality, real-world data. This is where Imitation Learning and VLA (Vision-Language-Action) models come into play.
However, capturing authentic human demonstrations is notorious for hardware friction. Traditional setups often rely on heavy, rigid frameworks or asynchronous separate cameras that miss crucial moments.
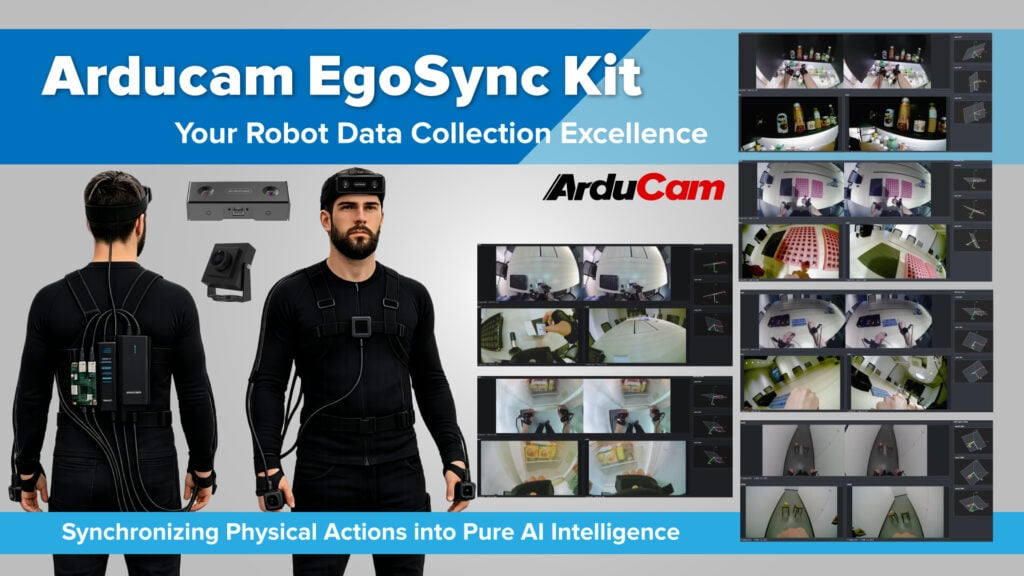
To bridge this gap, we are excited to introduce Arducam EgoSync-WEAR, a Wearable Full-Body Data Collection Kit designed to capture flawless, hardware-synchronized human demonstrations from multiple perspectives.
The Challenge of Human Demonstration Data Collection
When a human instructor demonstrates a task—such as picking up an object, assembling a device, or navigating a space—the AI model needs to see exactly what the human sees and does, simultaneously.
If your head-mounted camera and wrist-mounted cameras are out of sync by even a few milliseconds, the training dataset becomes corrupted. Furthermore, rapid human movements trigger the “jelly effect” or motion blur in standard rolling shutter cameras.
EgoSync-WEAR solves these bottlenecks natively with a fully integrated, synchronized, and wearable hardware ecosystem.
Key Features of EgoSync-WEAR
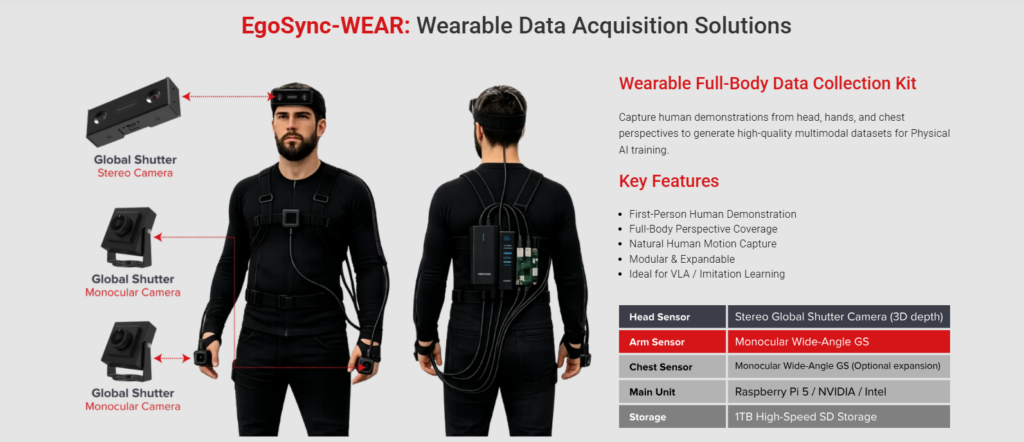
As illustrated in our layout diagram, EgoSync-WEAR is engineered as an all-in-one wearable data rig that respects natural human motion while maximizing data fidelity.
- First-Person Human Demonstration: Captures exactly what the operator looks at and interacts with, creating perfect ego-perspective data for imitation learning models.
- Full-Body Perspective Coverage: Synchronized vision streams cover the head, hands, and chest to leave zero blind spots in task demonstrations.
- Global Shutter (GS) Cameras: Every sensor in the kit utilizes a Global Shutter mechanism, eliminating motion blur and rolling shutter artifacts during fast-paced physical actions.
- Modular & Expandable: A highly flexible architecture that allows engineering teams to scale or reconfigure the camera layout based on specific task environments.
Hardware Architecture: Under the Hood
EgoSync-WEAR wraps advanced multi-sensor fusion into a lightweight, ergonomic harness system:
| Sensor / Unit Position | Technical Specifications | Function / Perspective |
| Head Sensor | Stereo Global Shutter Camera (3D depth) | Captures 1st-person point of view (POV) with stereoscopic depth perception. |
| Arm Sensor | Monocular Wide-Angle GS | Tracks precise hand movements, micro-manipulations, and tool usage. |
| Chest Sensor | Monocular Wide-Angle GS (Optional expansion) | Provides a stable, centered contextual view of the overall task environment. |
| Main Compute Unit | Raspberry Pi 5 / NVIDIA / Intel | Lightweight backbone handling power management and real-time data streaming. |
| Storage | 1TB High-Speed SD Storage | High-bandwidth local storage ensuring zero dropped frames during long-duration sessions. |
Ideal for Next-Gen Physical AI Training
Whether your team is training robotic arms via Behavior Cloning, deploying humanoid robots through Imitation Learning, or building massive multimodal datasets for VLA models, EgoSync-WEAR takes the hardware infrastructure headache out of your equation.
By offering microsecond-grade hardware synchronization in a wearable package, you can finally focus on training your models rather than fighting driver bugs and cable tangles.
Get Started with EgoSync-WEAR
The EgoSync-WEAR kit is fully customizable. Depending on your AI pipeline, our team can tailor the sensor selection, wide-angle lens fields-of-view (FOV), and compute unit integration to match your exact project requirements.
📬 Ready to accelerate your robotics data collection?
[Contact our hardware experts today] to inquire about the Arducam EgoSync-WEAR kit or request a technical consultation!